
Ottawa Researchers Train Rocky the Robot for Challenging Terrain
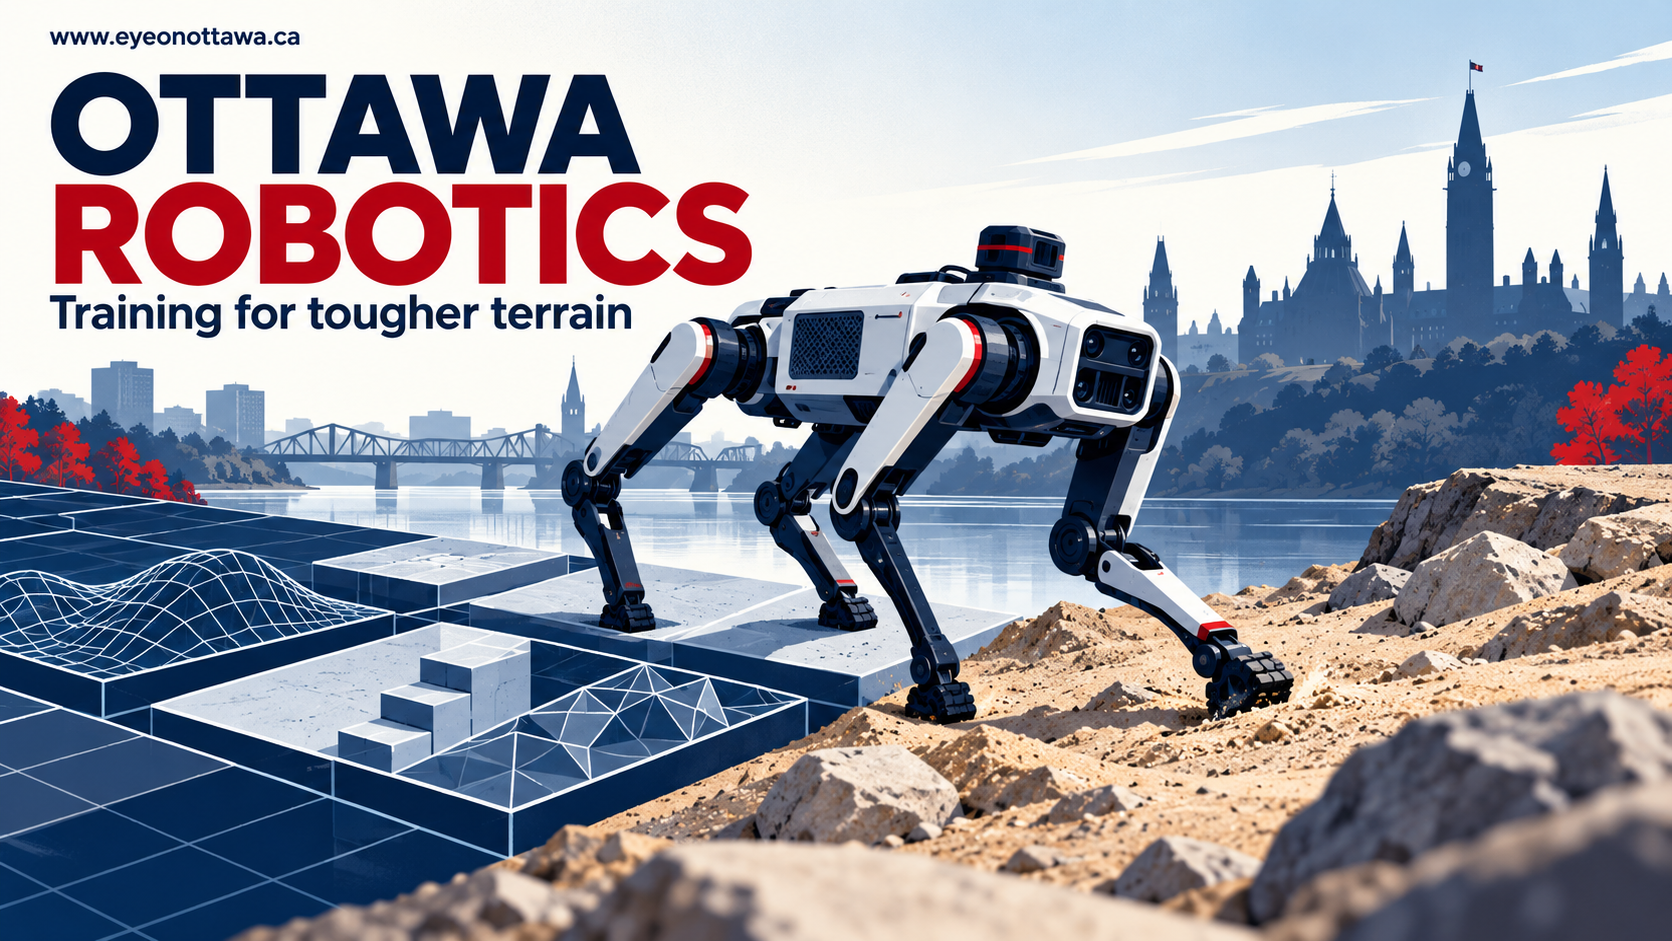
Ottawa researchers are training a four-legged robot to adapt to uneven ground, the National Research Council reported on October 28. The project explores how robots might eventually take on hazardous work, rather than announcing a new emergency-response service.
The robot, Rocky, uses cameras, laser-based LiDAR and motion and foot-force sensors to understand terrain and maintain balance. NRC postdoctoral researcher Abhishek Naik is training it through reinforcement learning, which uses feedback to improve its actions.
Digital simulations let the team test and refine behaviour before real-world trials. The NRC describes tests at Mission Control’s Moonyard in Ottawa, a facility that recreates lunar terrain, and collaboration involving University of Ottawa computer-science researcher Colin Bellinger.
Potential applications include disaster recovery, mining, agriculture and space exploration. These remain research goals: the NRC’s account shows remote-controlled demonstrations and describes greater autonomy as an objective. For Ottawa’s technology community, the work offers a local example of AI moving from simulation into physical testing.
